
This is an old revision of the document!
Published 19 Apr 2022
Tracked Explorer
Overview
My first attempt at using the Dagu Explorer robot control board was halted as one of the motors died. But my brother had bought a tracked vehicle chassis that he could no longer use, so I transferred the electronics across.
Hardware description
I reused the previous platform made from the plastic base plate of a Toshiba XM-3301B CD Rom drive.


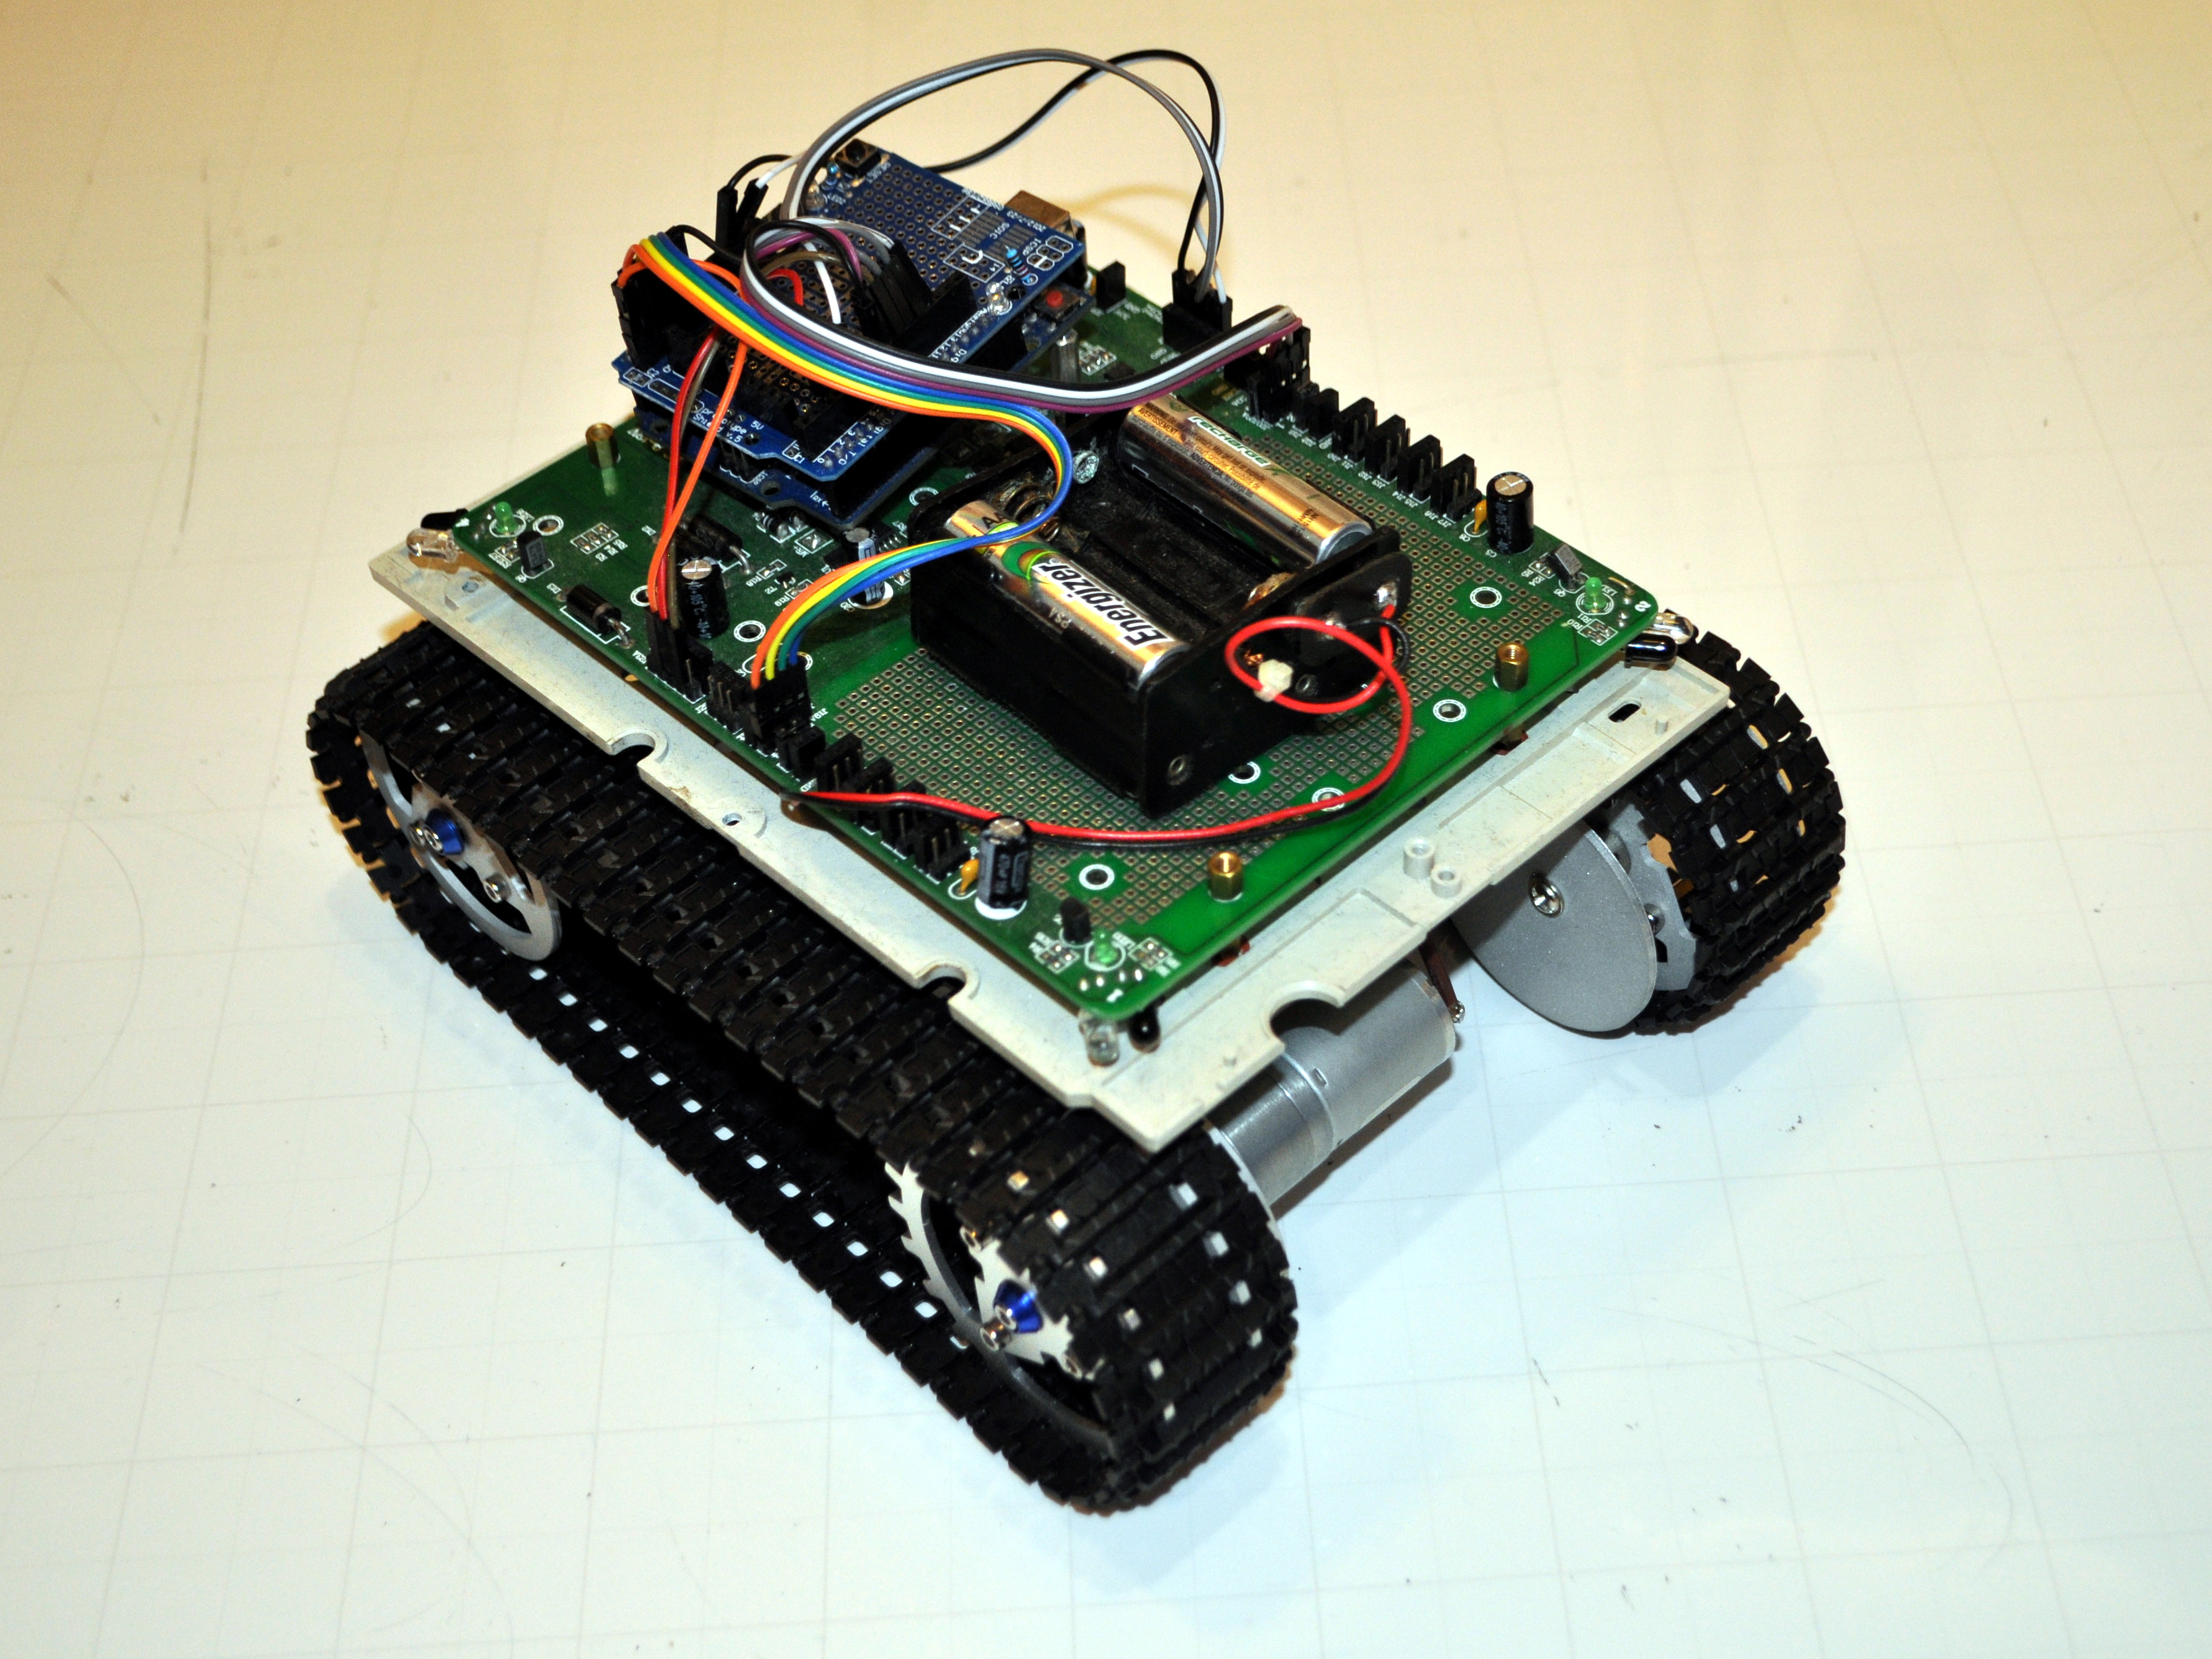
The chassis has two geared motors but instead of both driving from the same end, one is mounted at the front and the other at the rear. This means that the chassis assembly can be narrower than the width needed for two motors and gearboxes on the same axle. As with the Turbo Explorer the motors must be wired run in opposite directions (ie one clockwise, the other counter clockwise) for the robot to move in a straight line. The motors are rated at 12V, but work ok from the 7.2V motor supply on the Explorer board.
Assembled robot
 | |||
 |  |  |  |
 |
For the motors, the Explorer board uses 2 pin Molex connectors the same as found in many PC power supplies (internal plug connecting the mains wires, c0mes with high current wires attached). I modified an 8 AA cell battery pack to accommodate just 6 AA cells to provide a 7.2 to 8.4V battery for the system, found a plug (ex PC speaker I think) that matched the Explorer power jack. Strangely the Explorer board has large-pinned sockets for the outgoing power to the motors, but only a tiny battery socket through which all that power has to come!
Software
Conclusion
References and Additional Resources
- Explorer robot control board.
If any referenced page no longer exists, try looking for its URL on http://archive.org.
 Except where otherwise noted, content on this wiki is licensed under the following license: CC Attribution-Share Alike 4.0 International